Egocentric data for physical AI
Real first-person work for training robots.
Clips with video, hand pose, head motion and annotation, recorded by the people who do the work and licensed in writing. Depth is measured on devices with LiDAR.
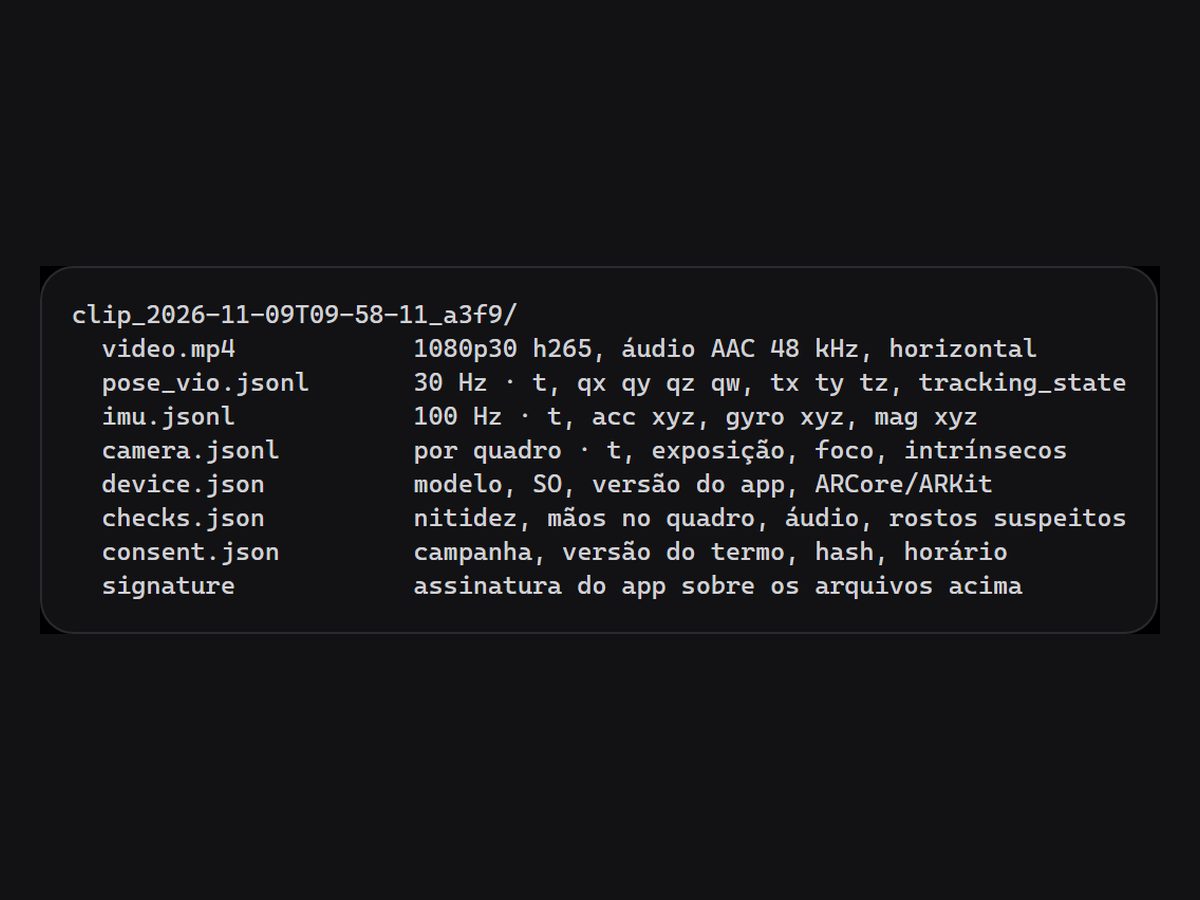
- Video, hands, IMU, pose and steps
- JSON, LeRobot or MCAP
- Per-clip consent
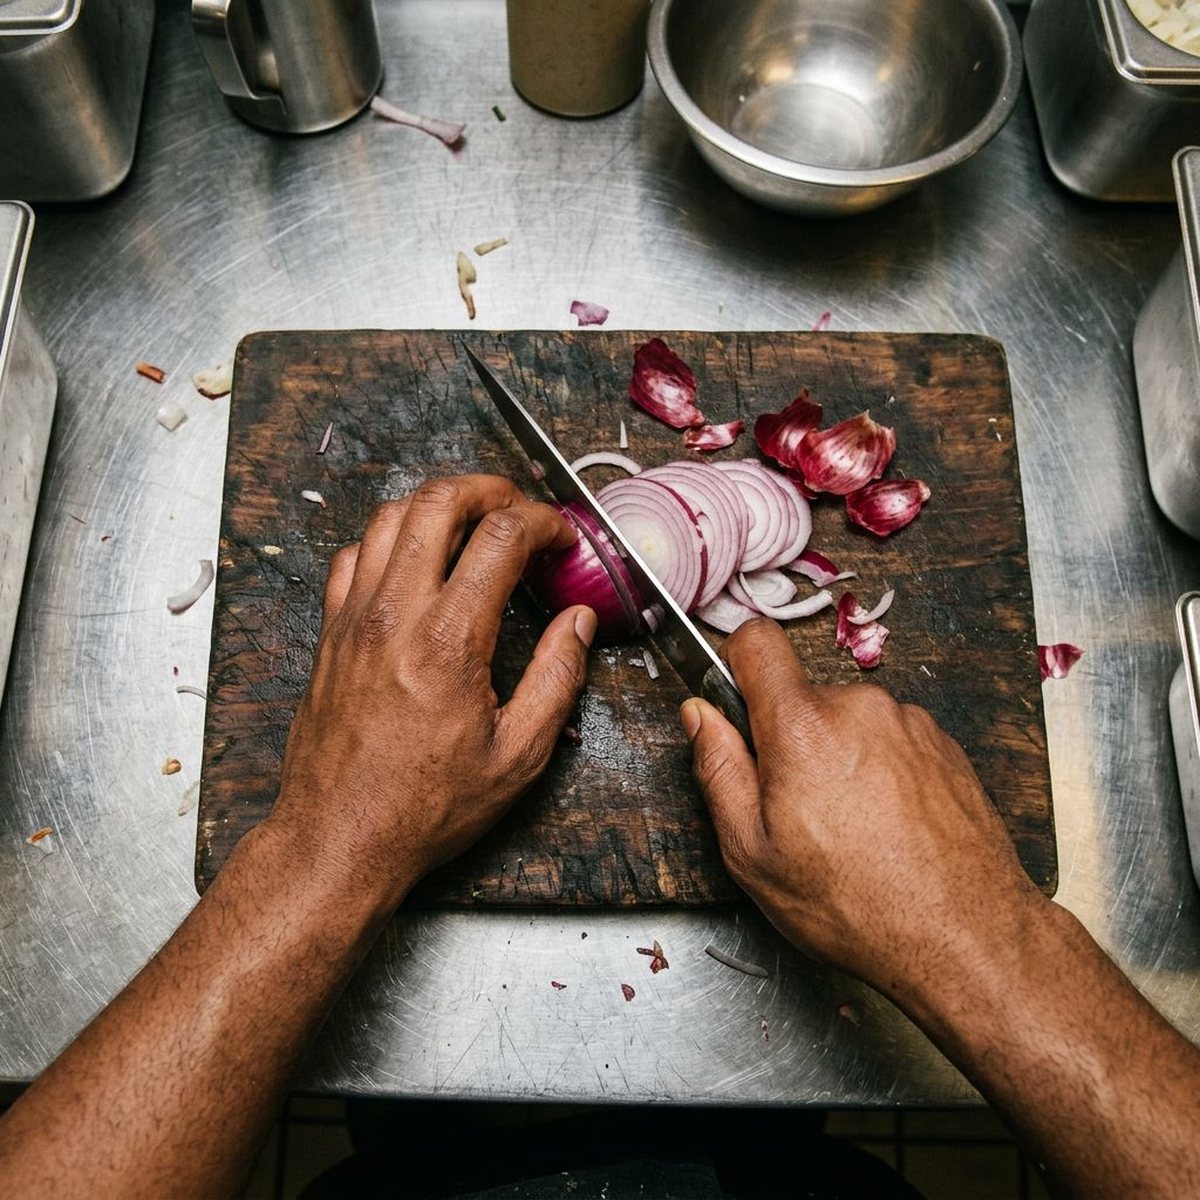
Data from peopledoing the real work
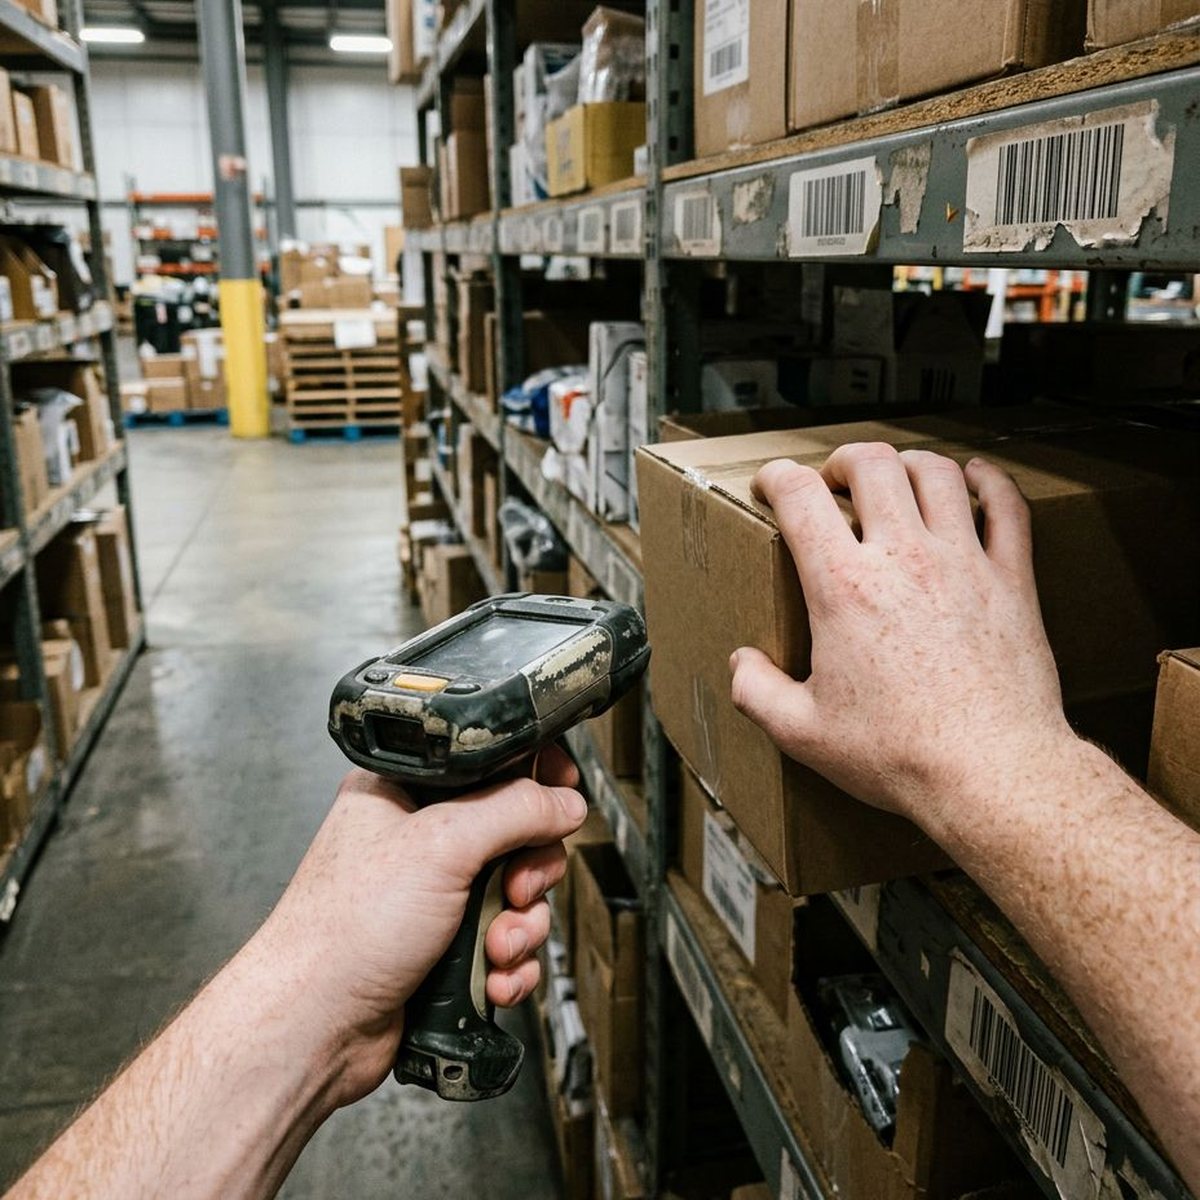
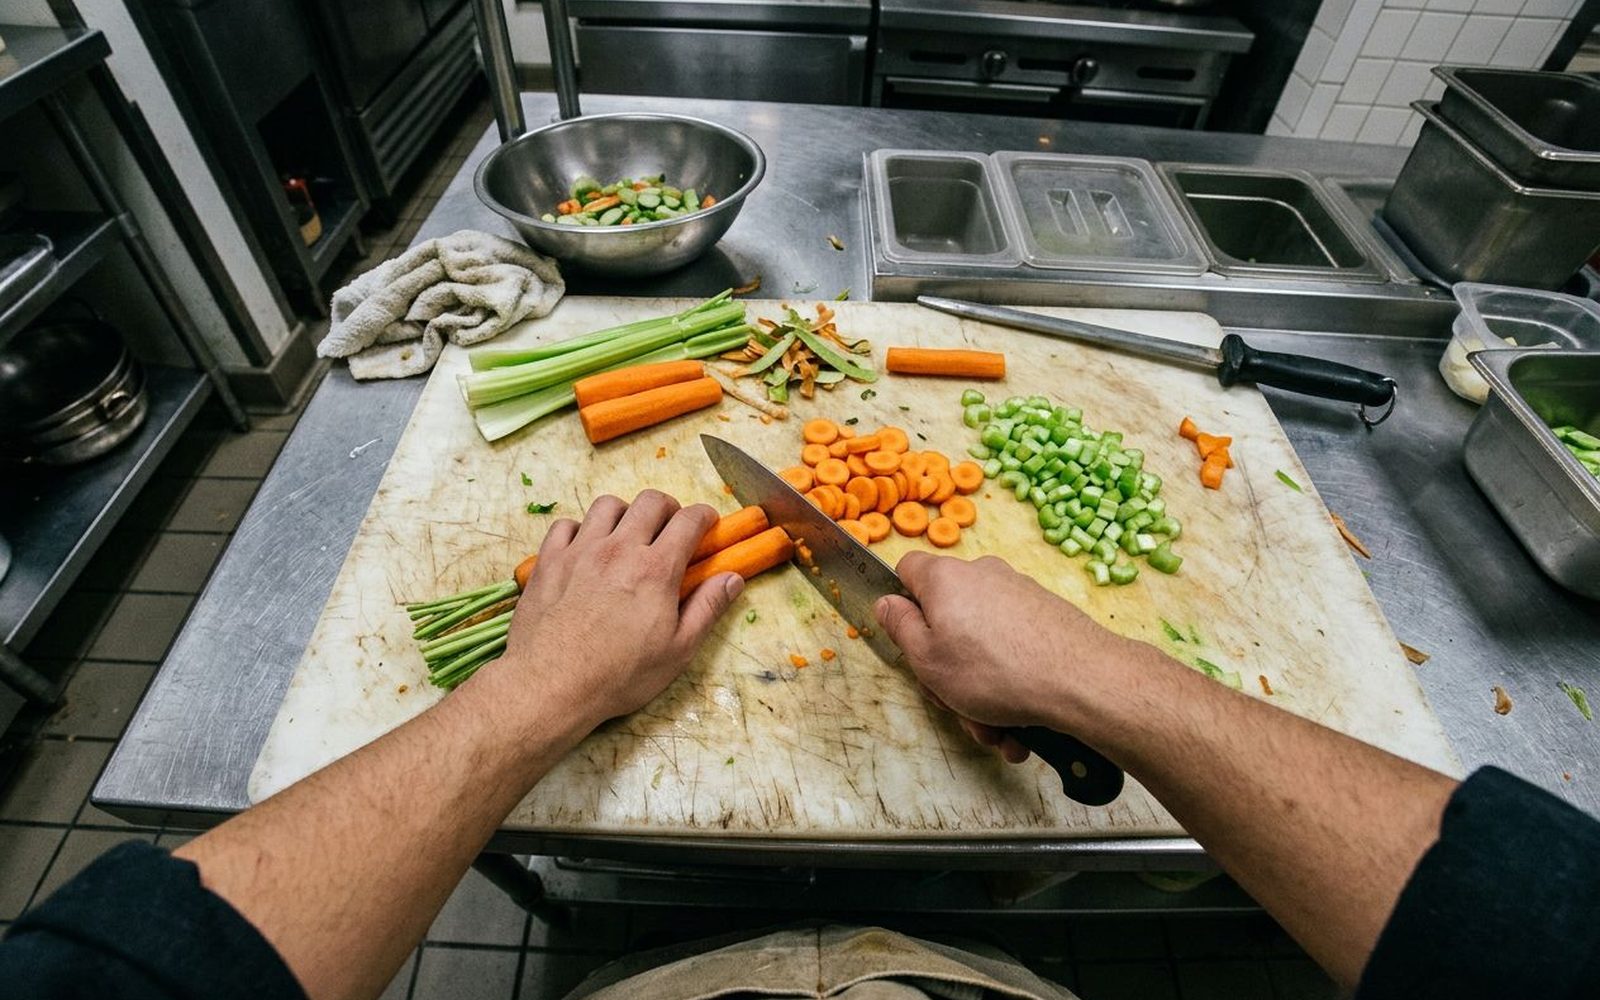
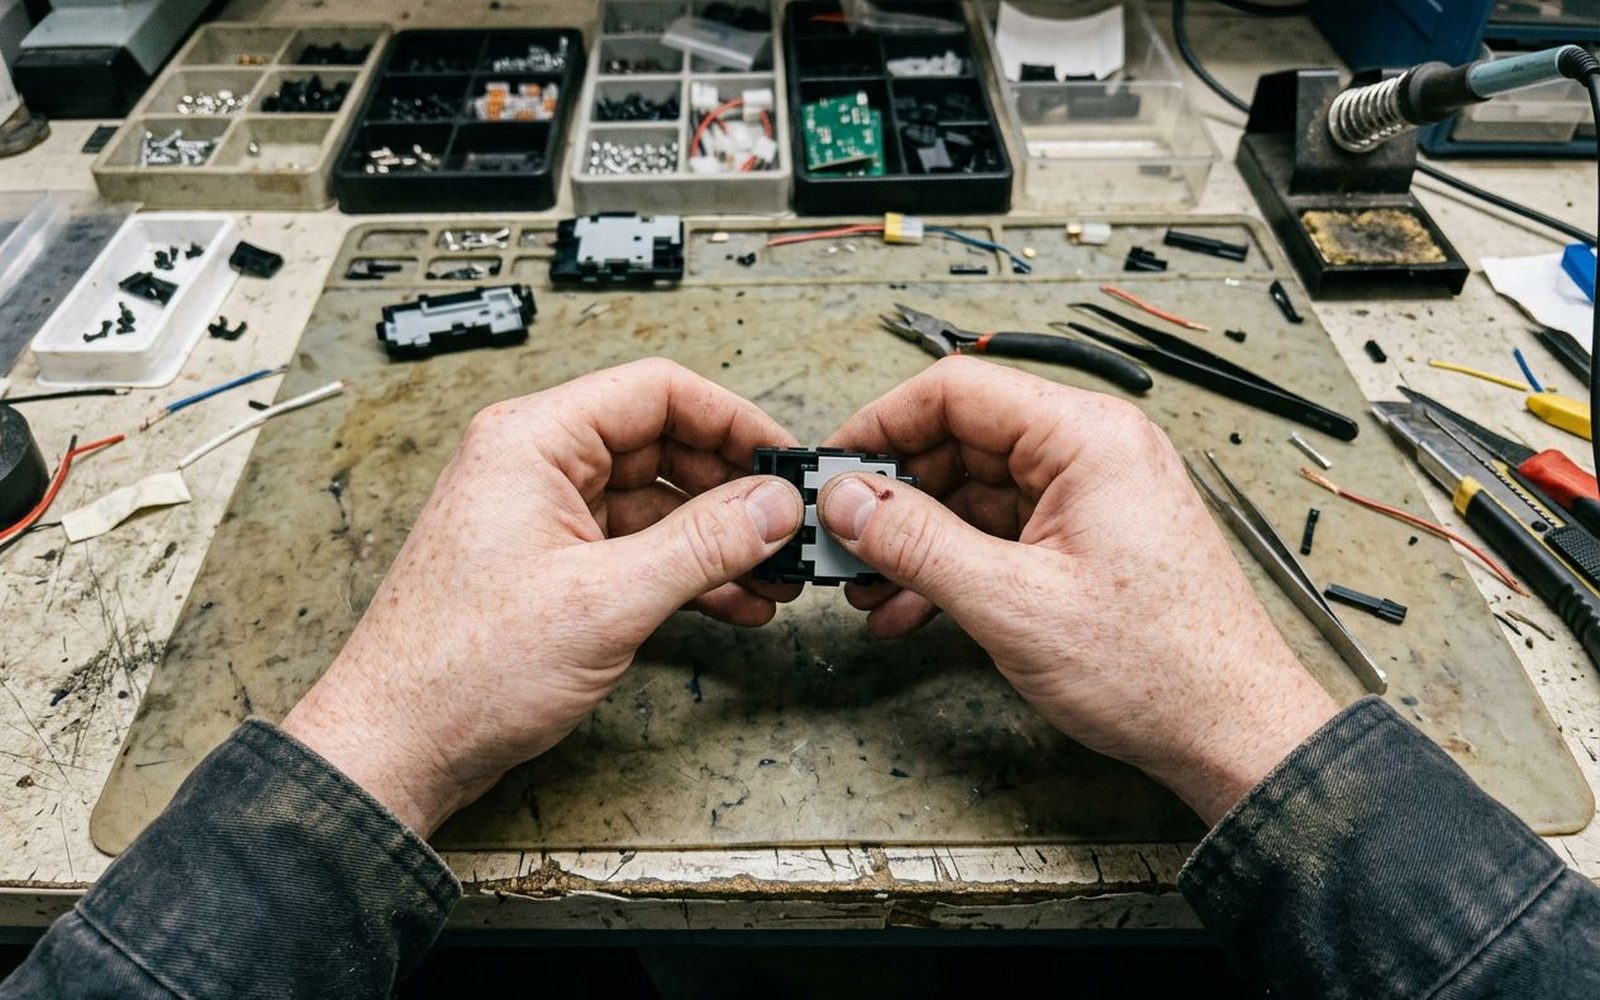
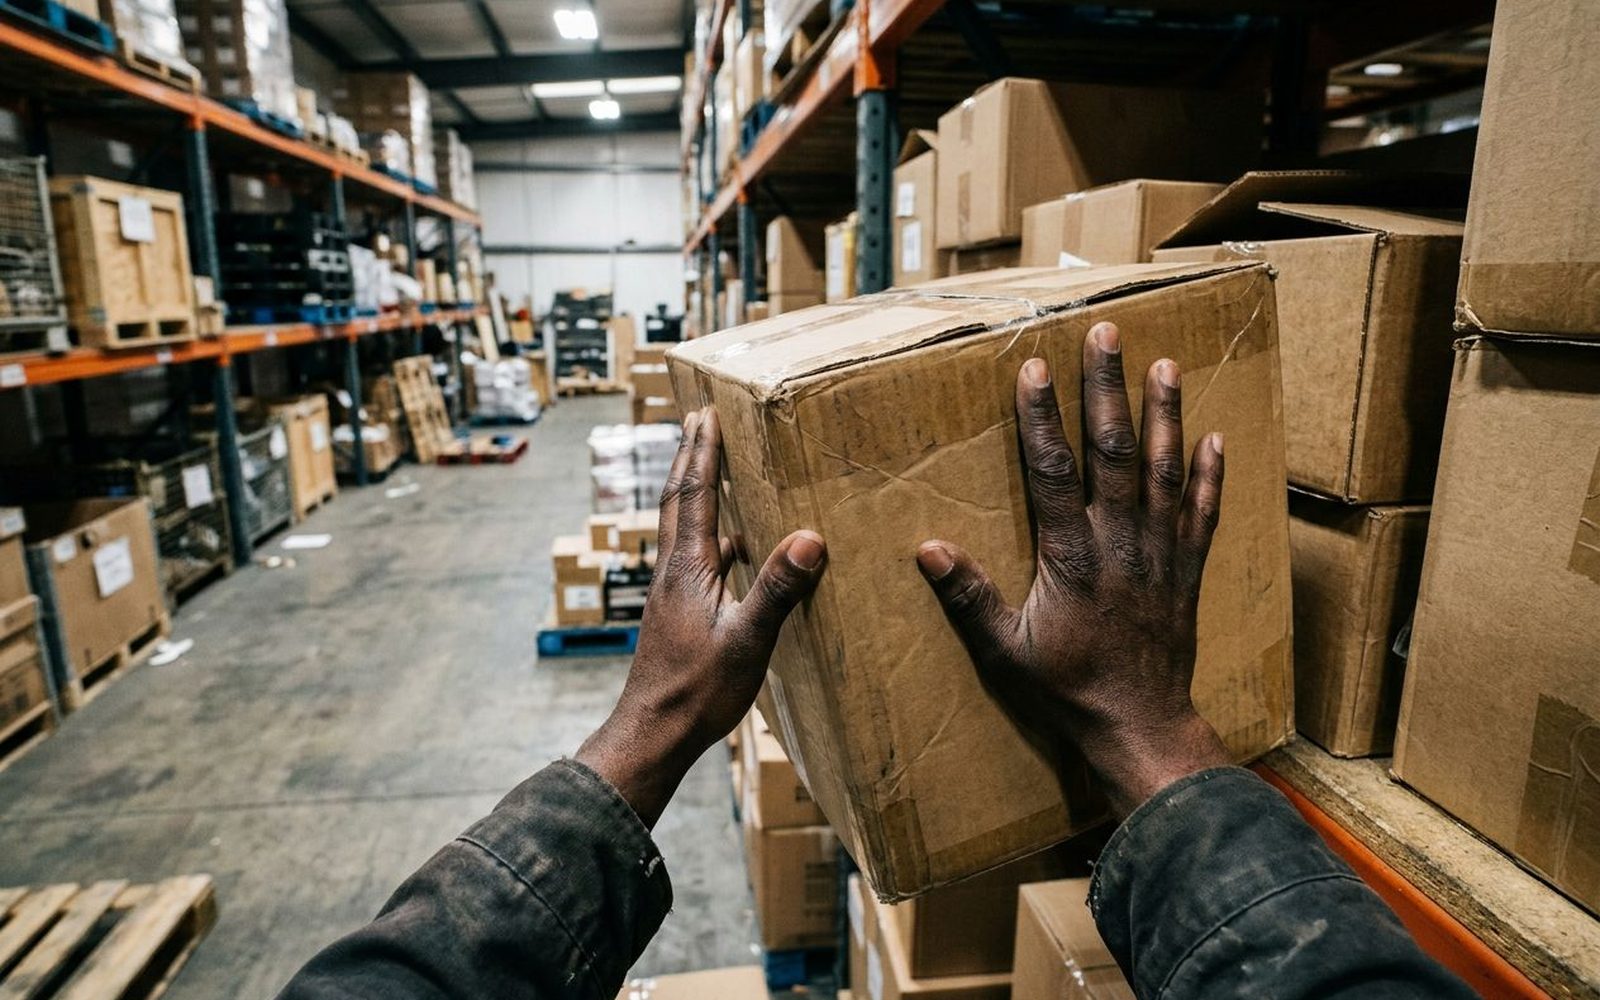
Robots learn by watching hands at work: cutting, fitting, folding, stacking. We pay people to film what they already do, at the real pace of a shift, and turn it into data a lab can use on Monday.
What's in a clip
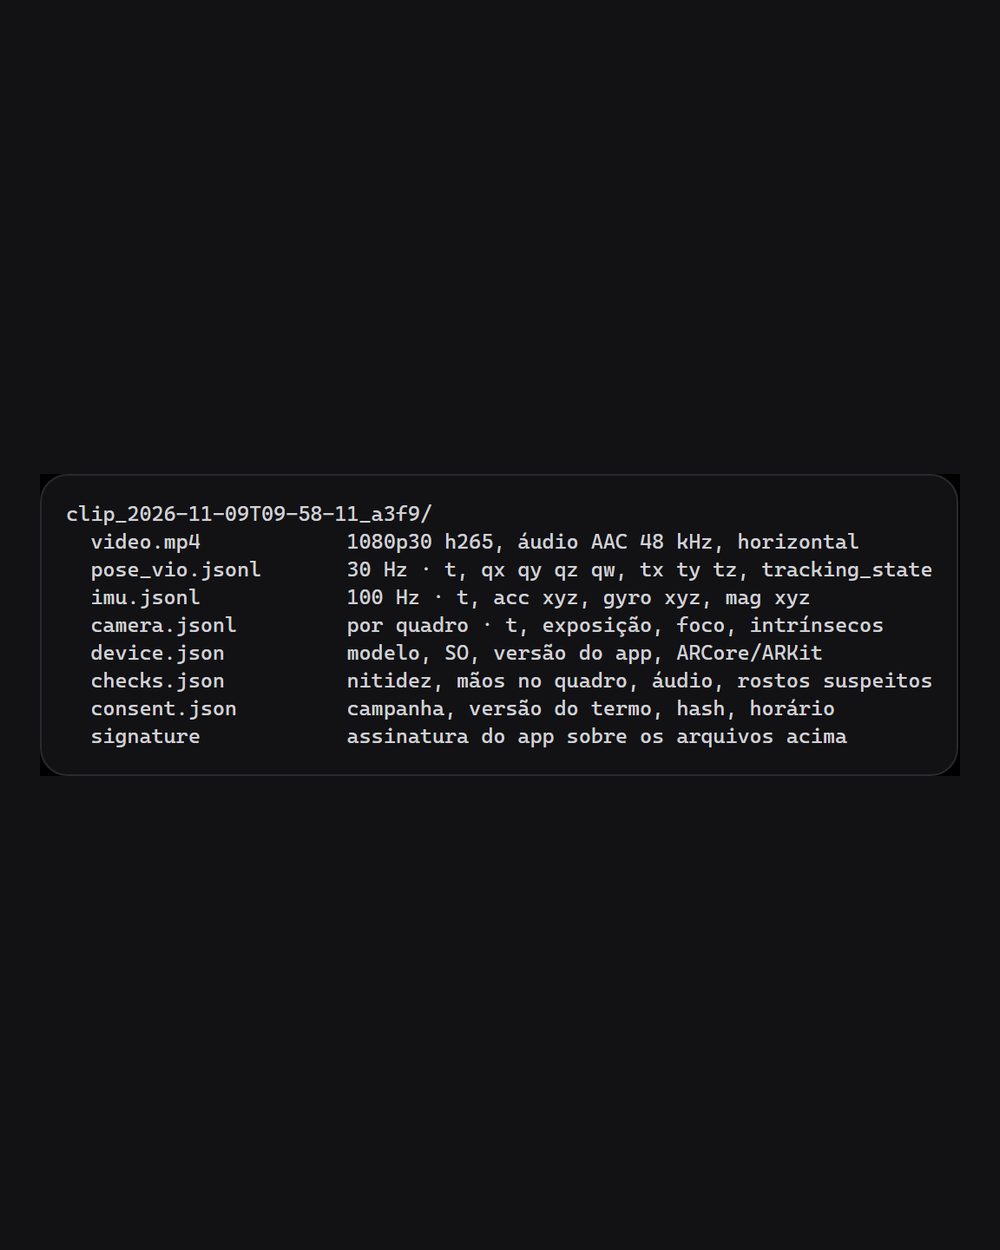
Five layers from the same device, synchronized to one clock. Every clip ships ready for training.
-
Video
First person
Head-mounted camera, landscape, uncut. What the person sees is what the robot will see.
-
Pose
Hands and wrists
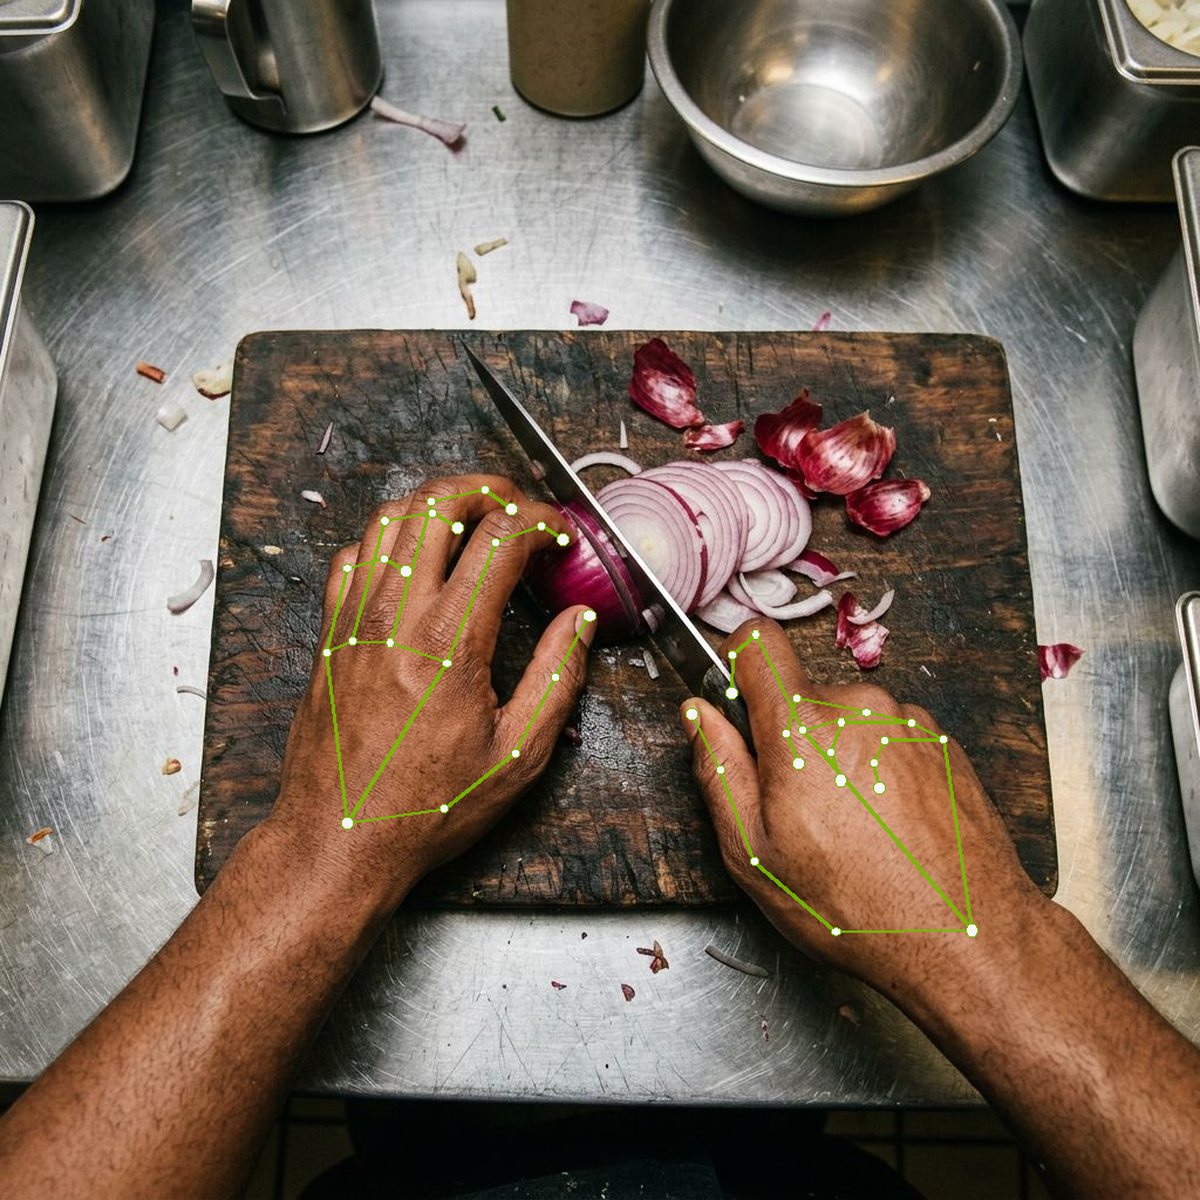
Twenty-one keypoints per hand, frame by frame, each with its confidence score.
-
Motion
Head and body
Accelerometer and gyroscope at 100 to 200 Hz depending on the phone, aligned to the video on the same clock.
-
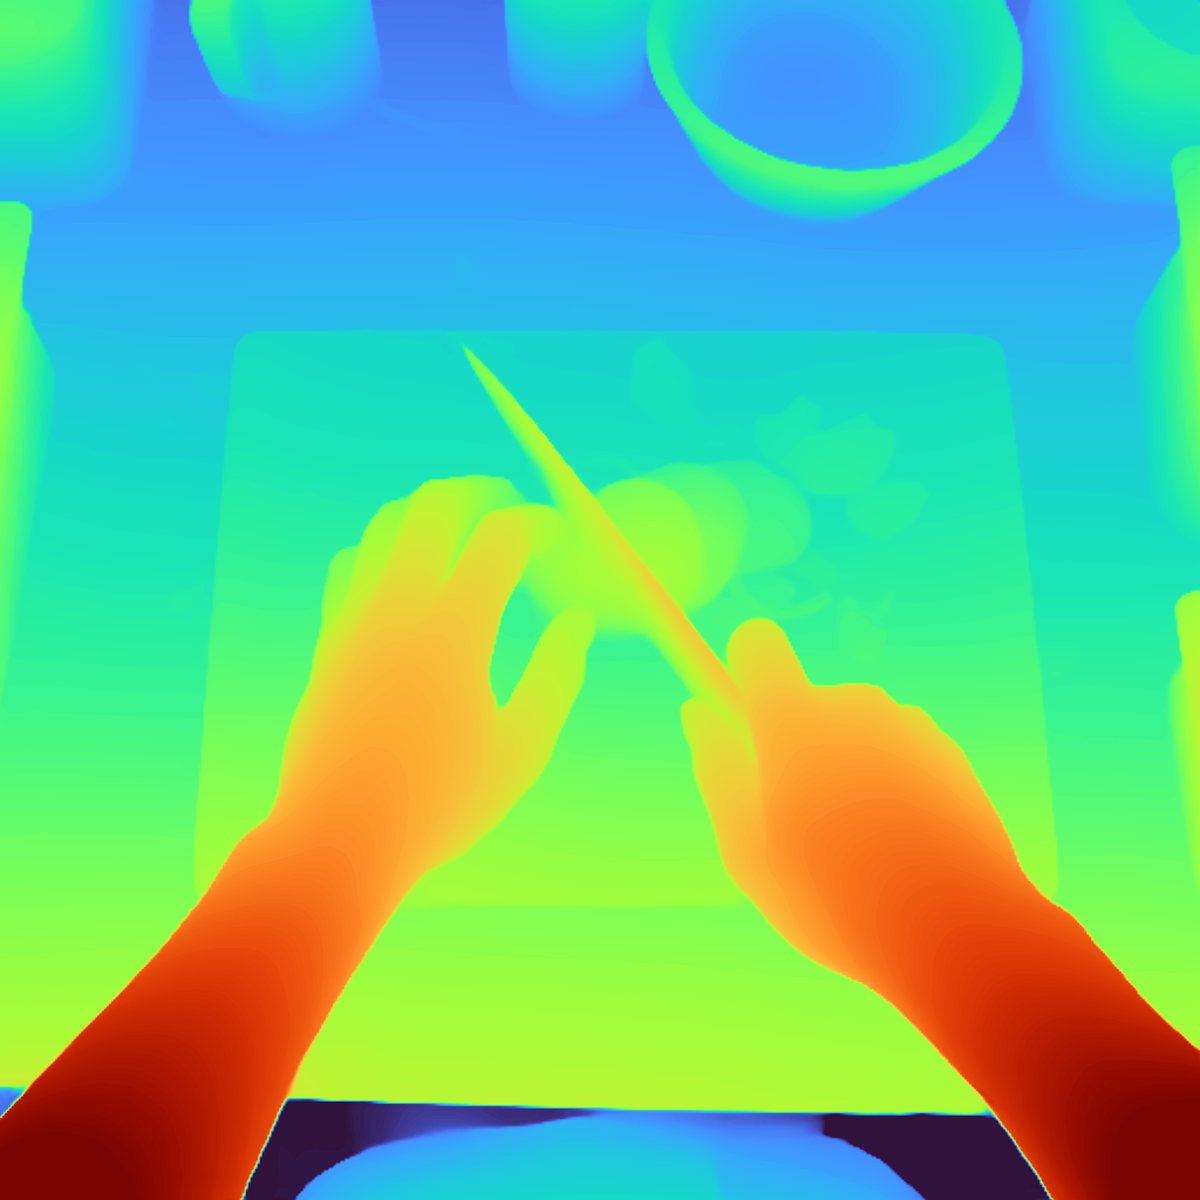
Depth
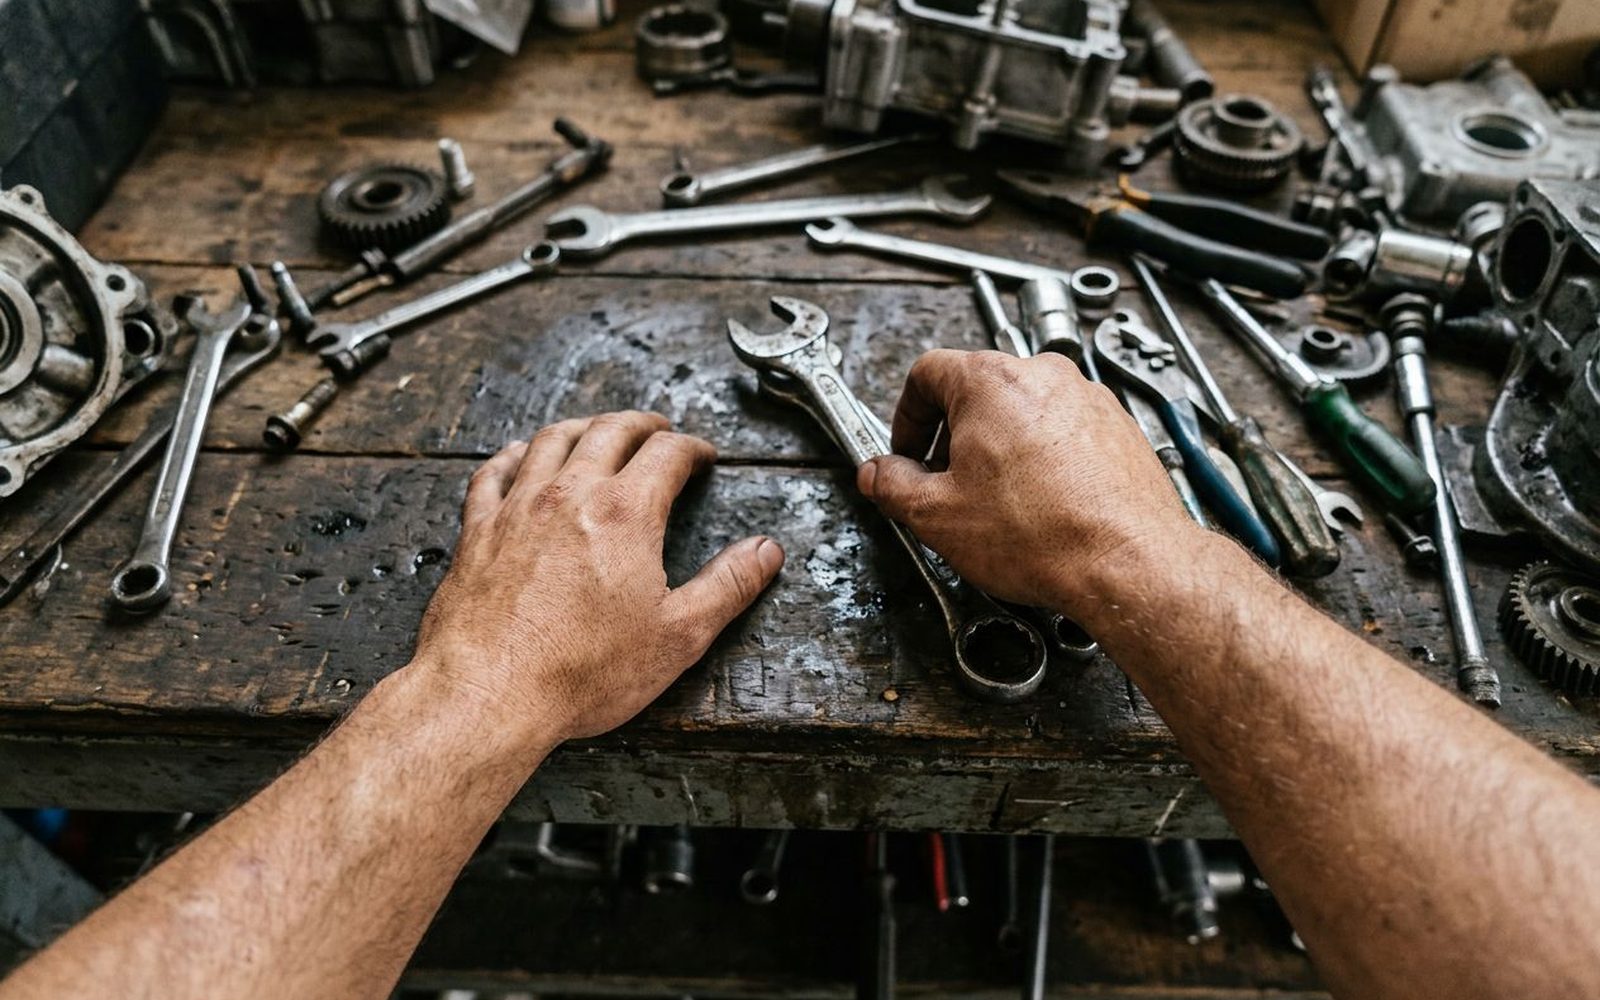
Distance per pixel
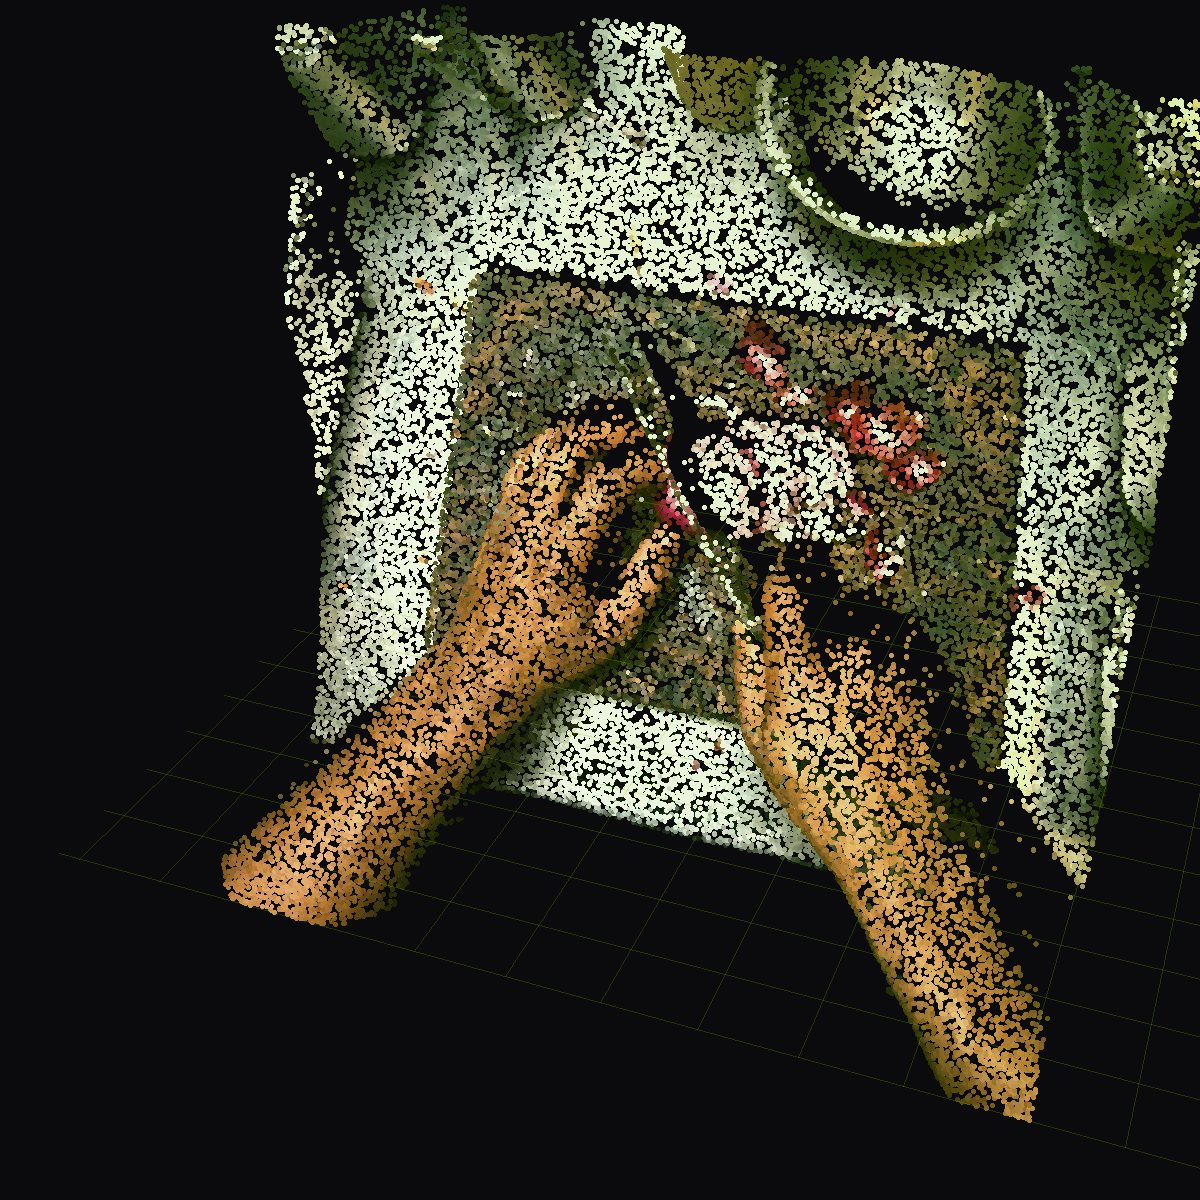
Measured by LiDAR on devices that have it. Estimated in processing on the rest.
-
Annotation
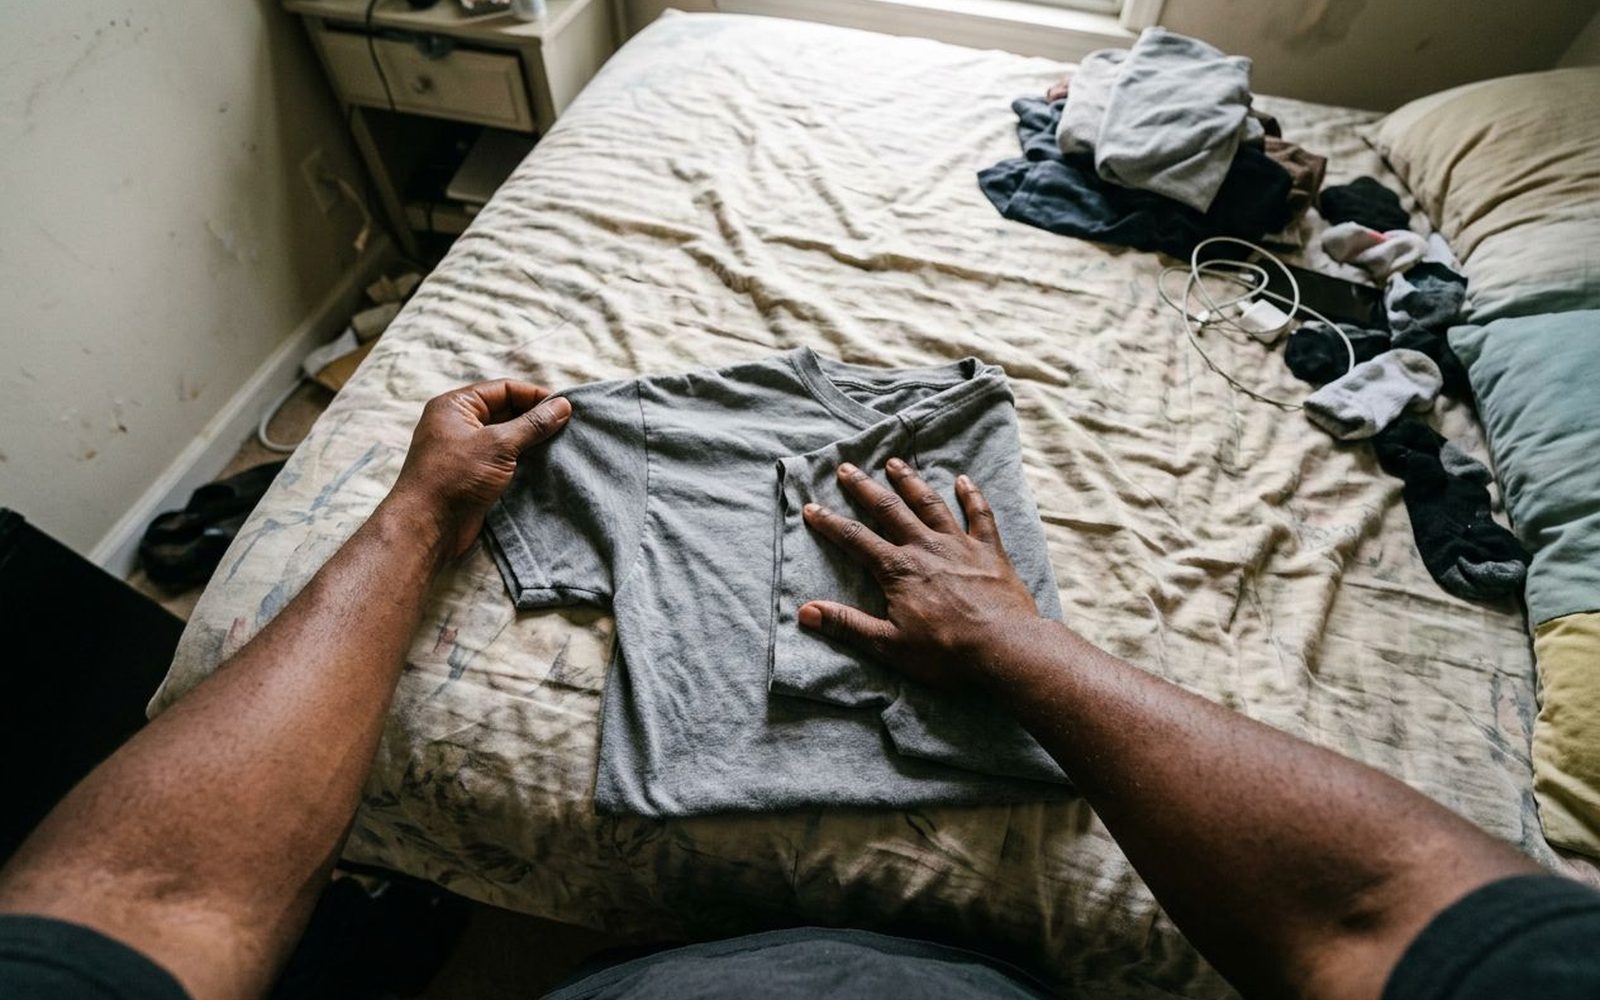
Task, step and object
Every clip states what was done, in what order and with what. In JSON, LeRobot or MCAP.
Anatomy of a clip
Six tracks on one clock. Hover or tap a track to see its file and columns.
Where we film
Real manual work, where it happens. Each sector with its own tasks, tools and mess.
-
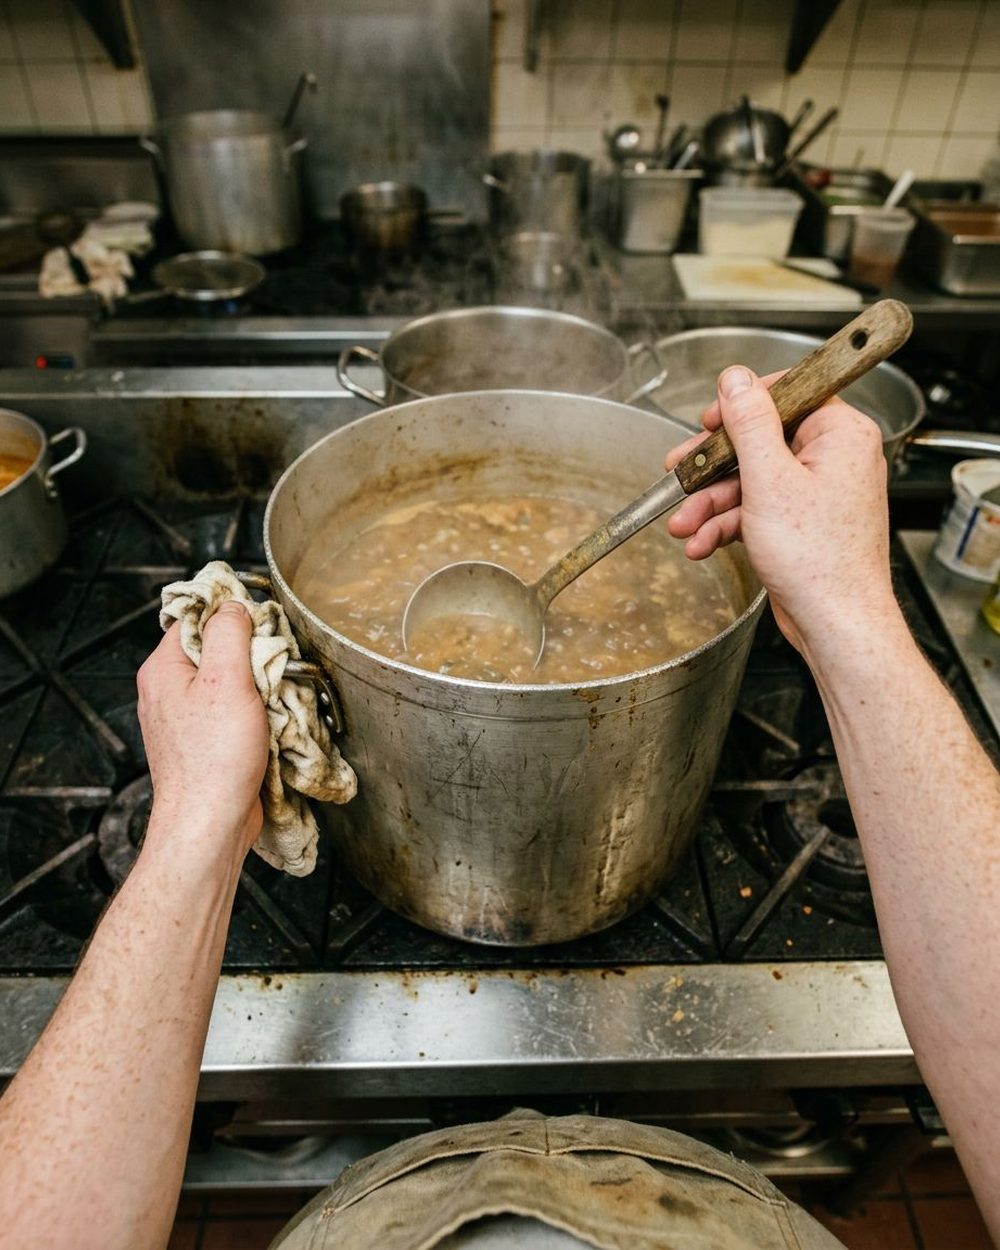
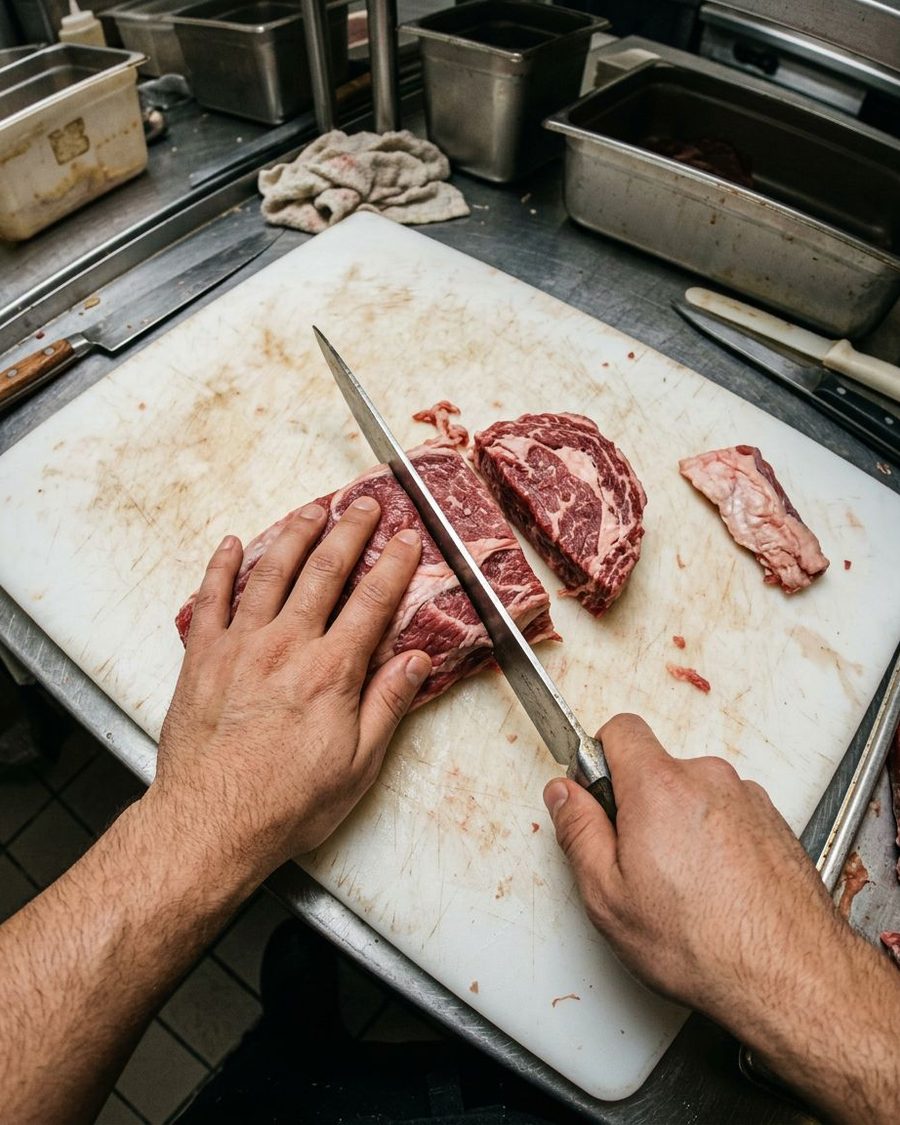 Cut and portion
Kitchen
Prep, plating, dishes.
-
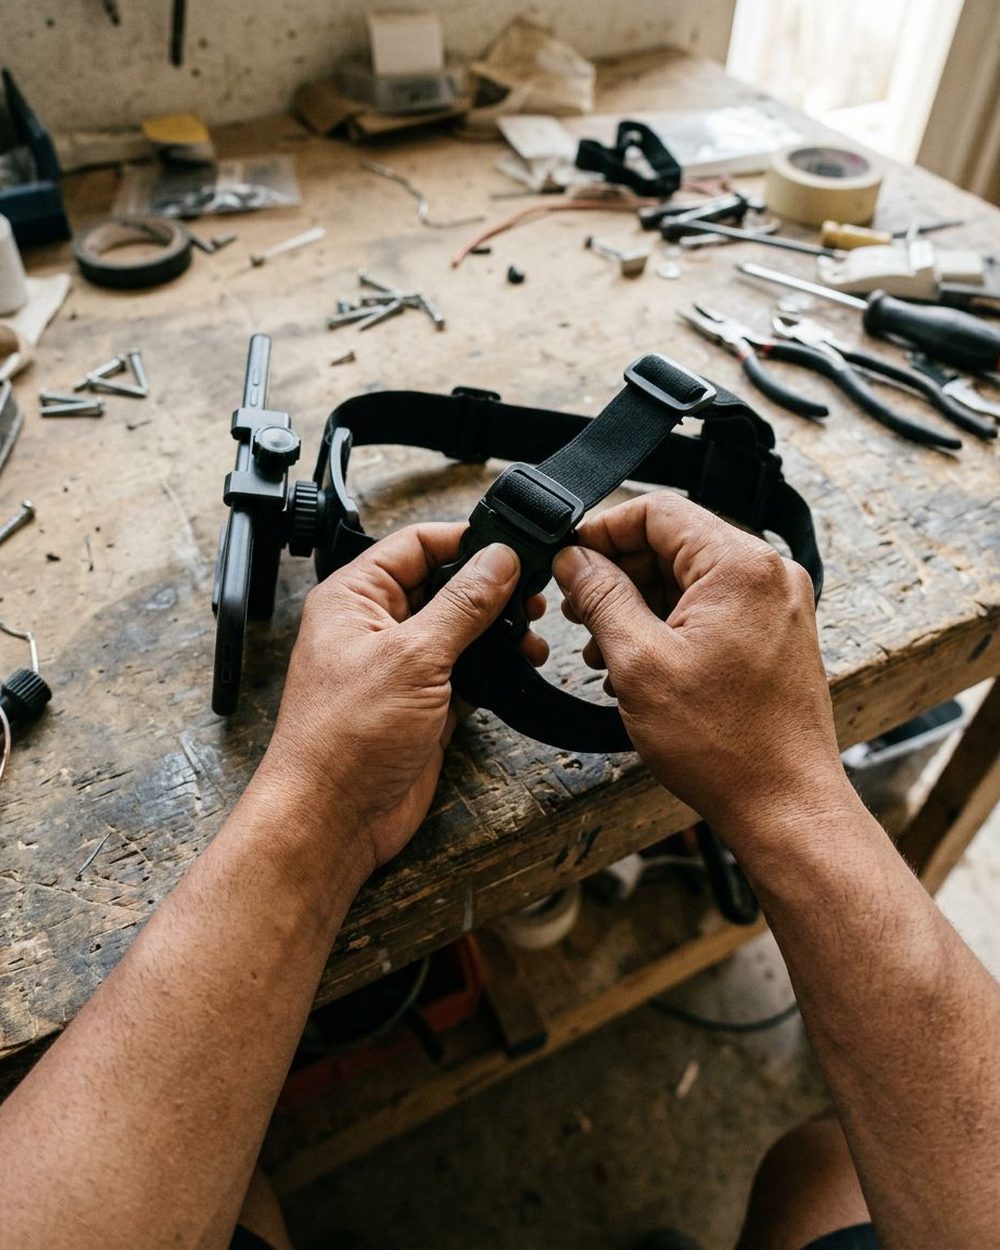
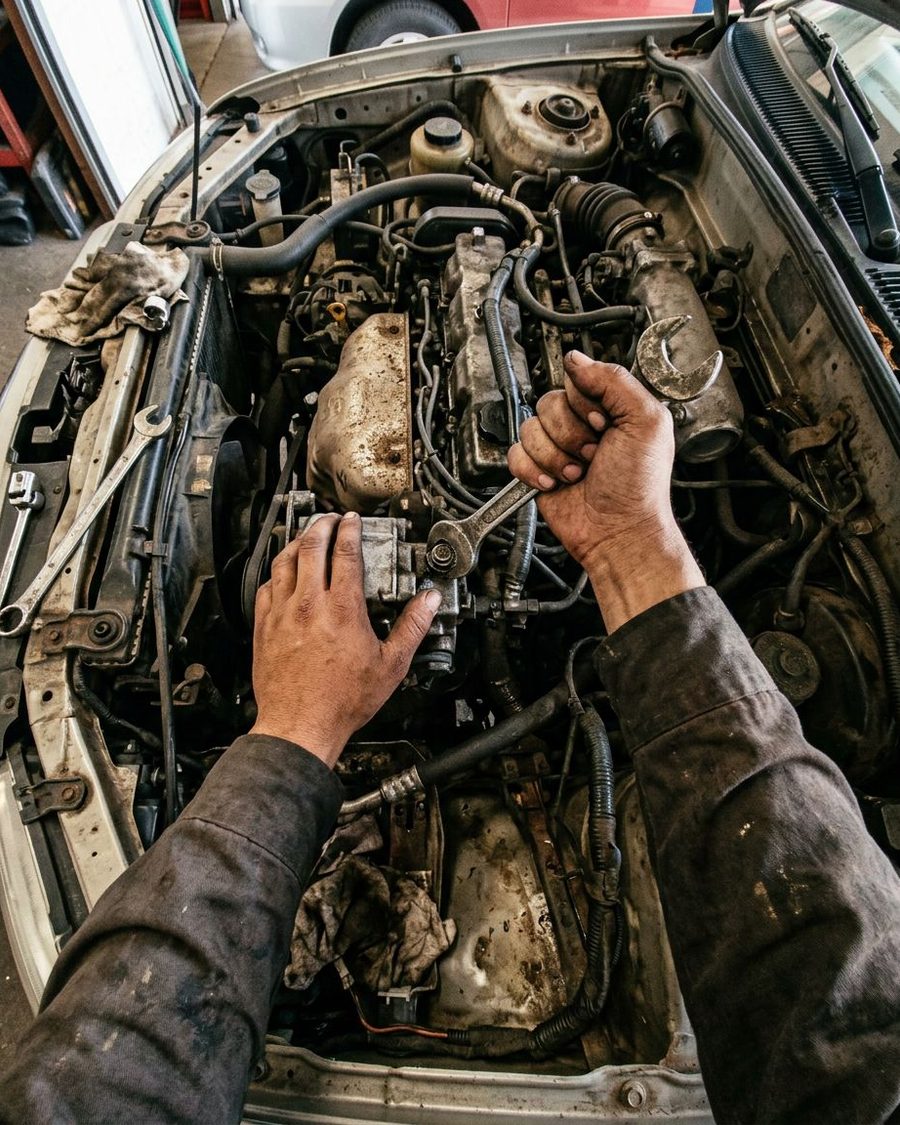 Tighten and fit
Workshop
Assembly, part replacement, fastening.
-
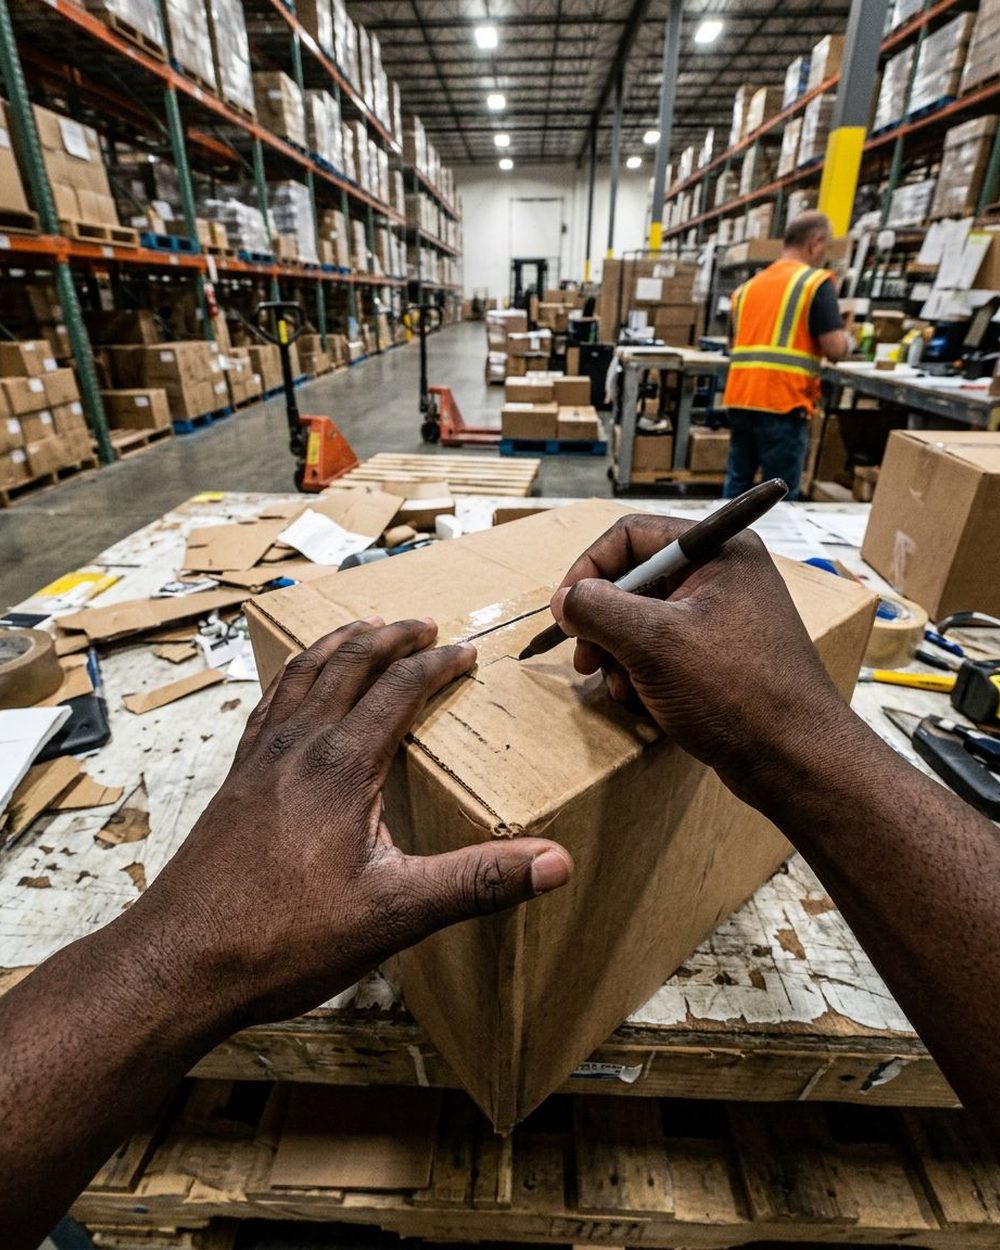
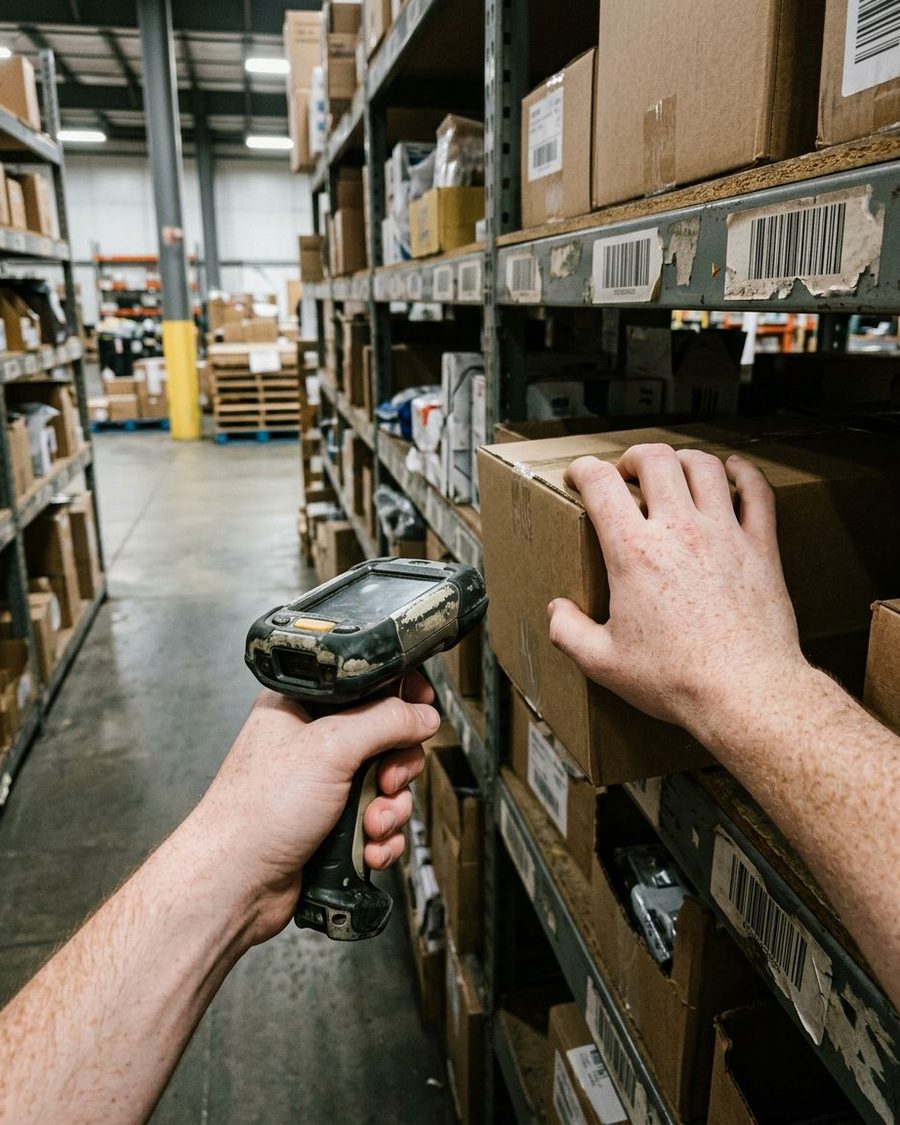 Pick and pack
Warehouse
Picking, packing, labeling.
-
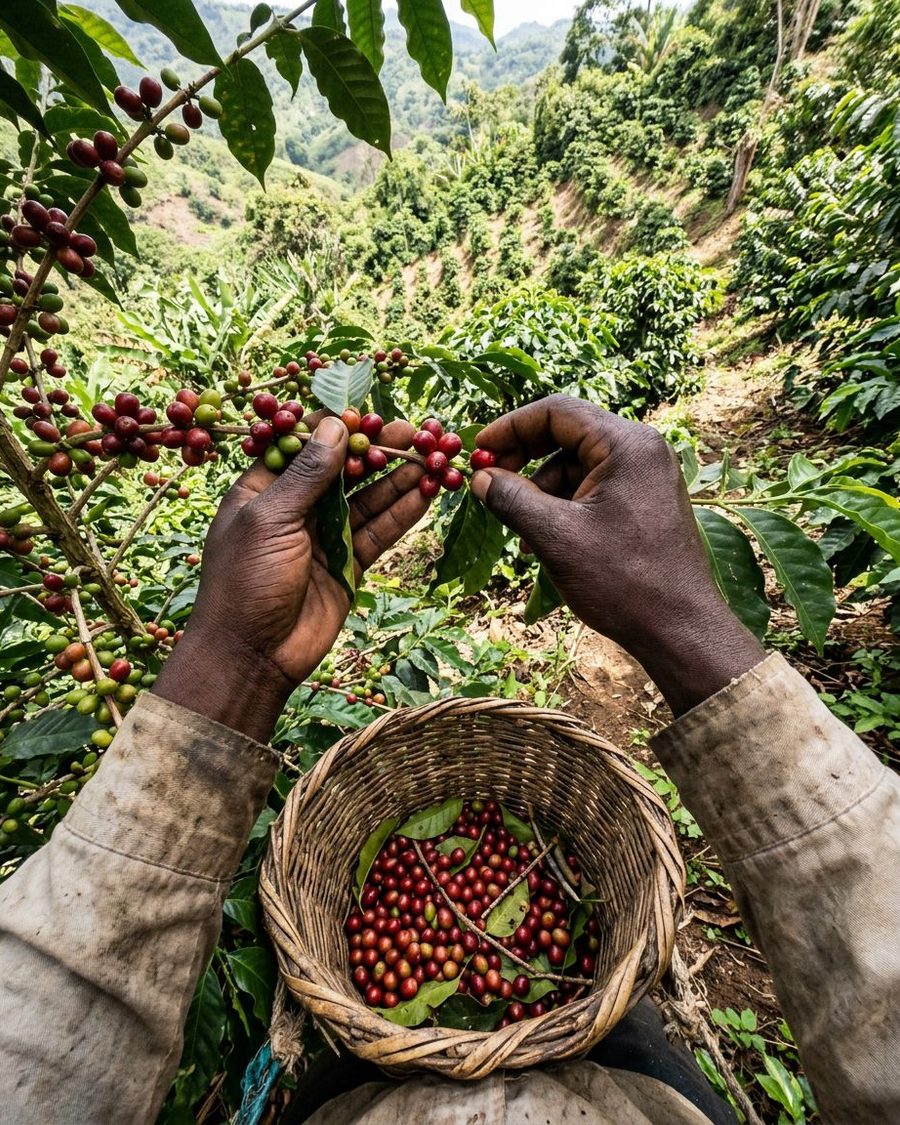 Harvest and sort
Field
Harvesting, sorting, crating.
-
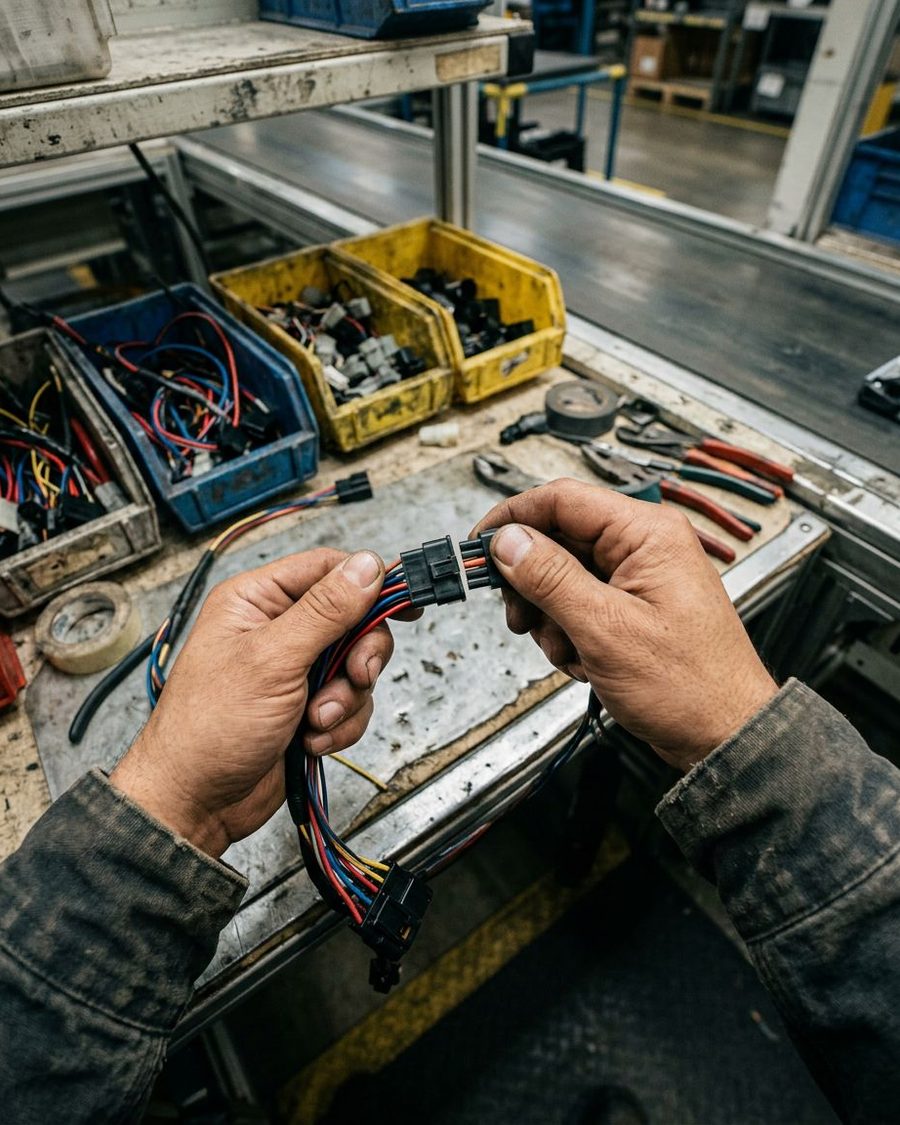 Assemble and check
Assembly
Fitting, cabling, testing.
-
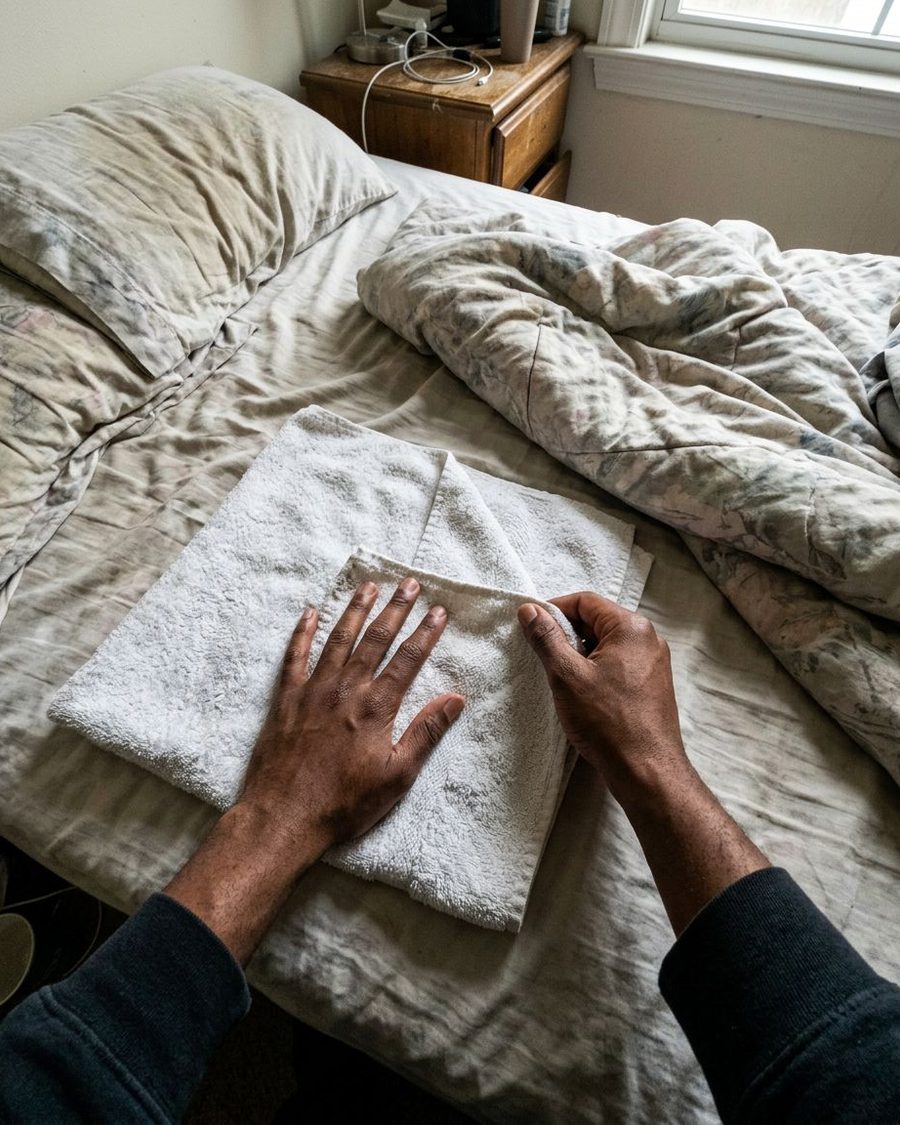 Fold and put away
Home
Laundry, dishes, tidying.
How it works
From briefing to delivery in five steps. The first sample arrives before any larger contract.
-
Briefing
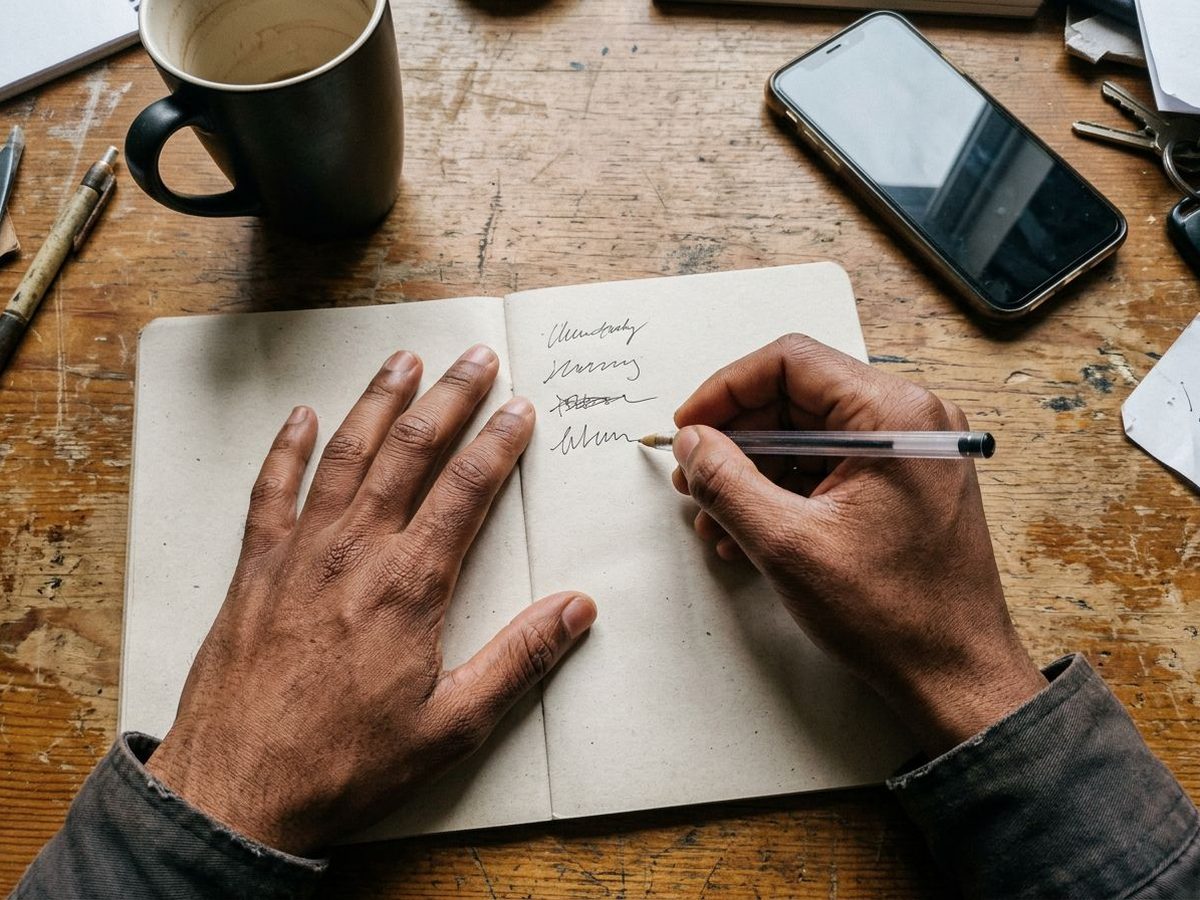
You tell us the task, the environment and the format. We come back with a capture plan in two days.
-
Pilot
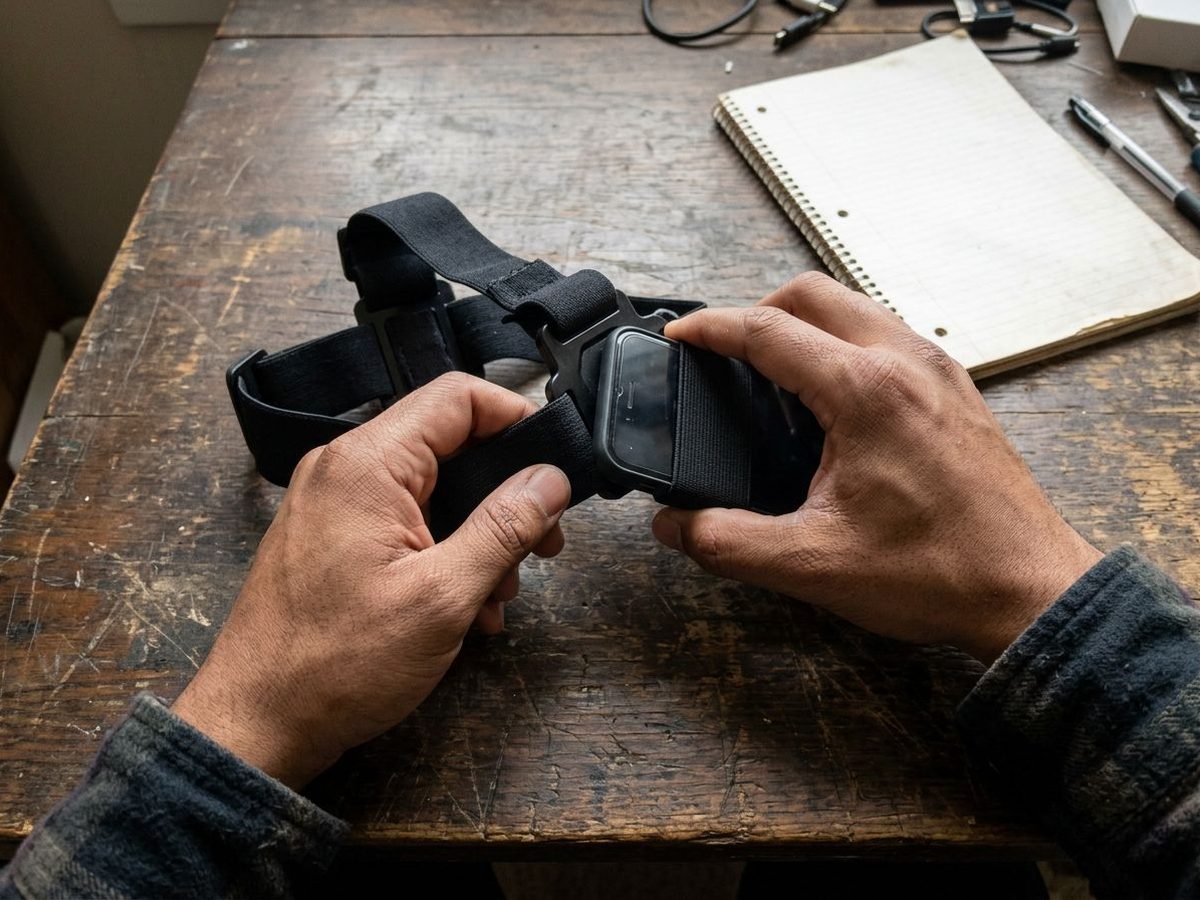
A few hours recorded, reviewed and delivered in your format. You test it in your pipeline before scaling.
-
Scale
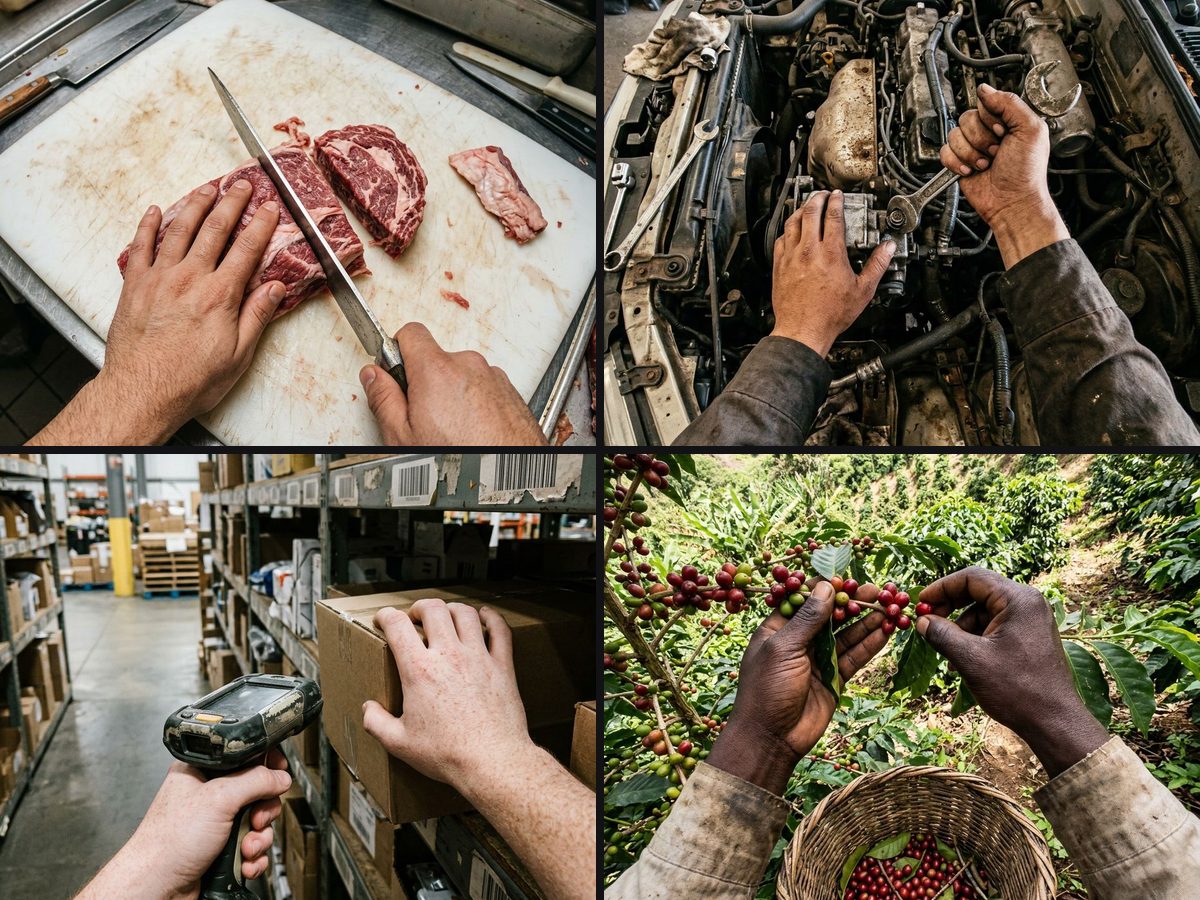
Recorders recruited by sector, trained and recording on real shifts. Hundreds of hours per month.
-
Review
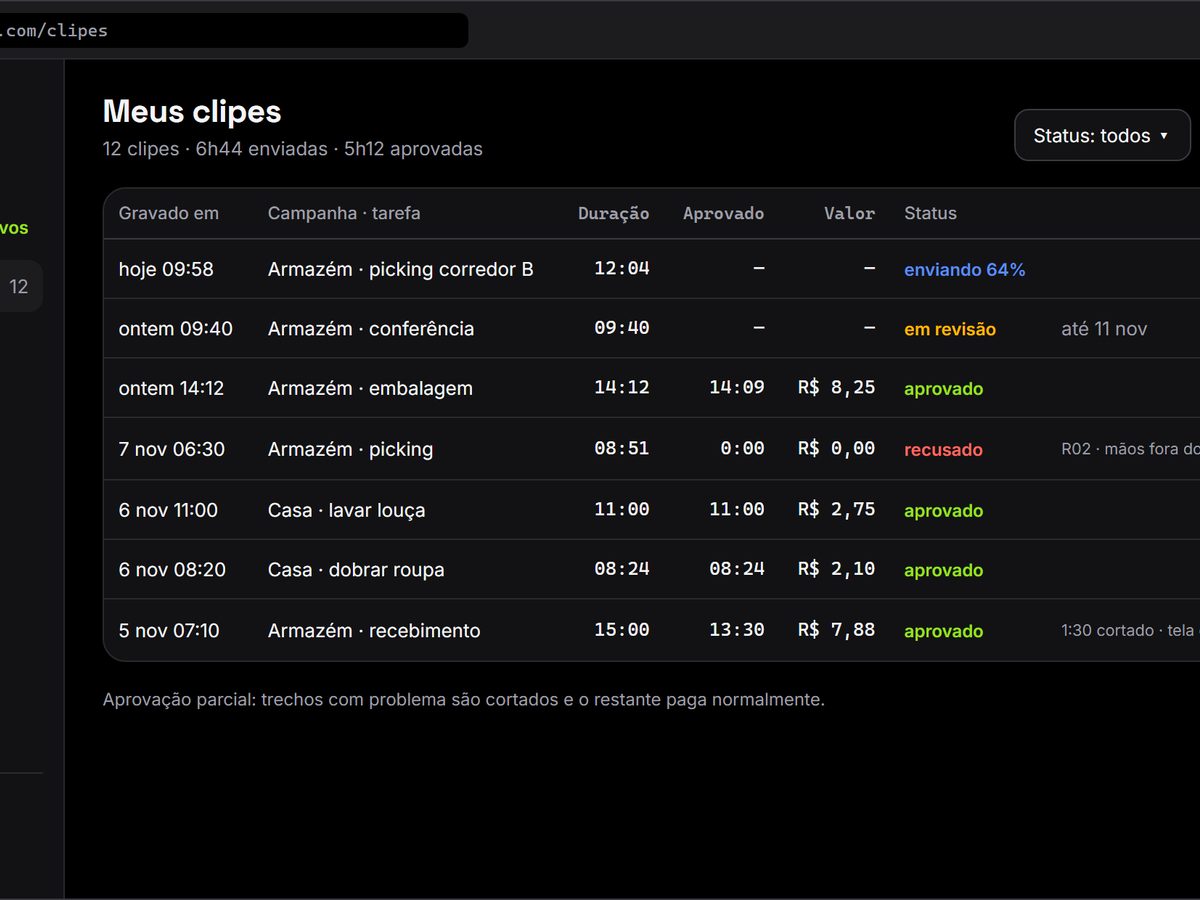
Every minute goes through automated and human checks before it counts. Faces and personal data are removed before delivery.
-
Delivery
Clips in JSON, LeRobot or MCAP, in your bucket or ours. Written license per clip, with consent attached.
The platform
From the recorder's phone to your lab's bucket, every clip rides one line, and we own all of it: capture, enrichment, review and delivery. A complete infrastructure, ready to scale anywhere in the world.
-
Recorder web app
In the browser
Recorders pick an activity, reserve a slot and follow their submissions and earnings.
Activity accepted -
Capture app
iOS and Android
Records 1080p30 H.264 with synchronized IMU and device metadata. Guides the task step by step and warns live when hands leave the frame or the light is too low.
Video + IMU -
Enrichment server
Processing pipeline
Adds the layers on top of the raw clip: hand pose, 6-DoF camera pose, depth, steps and a quality score. The privacy pass blurs faces, license plates and personal data in text.
+ pose, depth, steps -
QA and operations backoffice
EgoHands team
Our team reviews every delivery before it ships and decides the privacy cases that are in doubt.
Reviewed by a person -
Partner portal
partnerdata.egohands.com
The lab places orders, follows progress batch by batch and receives deliveries in LeRobot, MCAP or JSON.
Delivered to the lab
A person reviews every delivery before it ships.
Request a sampleField notes
Why we record in first person, not on a tripod
The robot won't have a camera in the corner of the room. It will have the view of the person doing the task.
What review rejects, and why
Light, hands out of frame, a missing sensor. Six fixed reasons, always explained to the recorder.
How we protect people who end up in the shot
Faces blurred before delivery, a notice on site and the right to withdraw a clip at any time.
JSON, LeRobot or MCAP: which to ask for
All three come from the same clip. The difference is what your pipeline already reads.
Questions
How much does a dataset cost?
It depends on the sector, the volume of hours and whether it is exclusive. We send a proposal after the briefing, together with the sample.
How does a project start?
With a one-hour briefing and a pilot of a few hours recorded in your format. You test it in your pipeline before signing anything larger.
What format does it come in?
JSON, LeRobot or MCAP, in your bucket or ours. All three come from the same clip, with video, hands, motion and steps on the same clock. Depth is included in clips recorded with LiDAR.
Did the people in the video consent?
Recorders sign a consent form in the app, per campaign, and can withdraw consent at any time. Third-party faces are blurred before delivery and a notice is posted at the recording site.
Where do you operate?
Worldwide. Recorders film where the work happens and delivery is remote, to your bucket or ours.
Let's talk
Tell us the task your robot needs to learn. A person reads every message and replies within two business days.
partner@egohands.com- EgoHands
- A product of Codemart LLC
30 N Gould St # 39741
Sheridan, WY 82801, USA - Operations
- Recorders where the work happens
Remote delivery, worldwide